01
Overview
⚙️ Spinal Reflex Decoupling: High-level goals from VLA run at 10 Hz, while local torque reflexes execute at 555 Hz in 1.8 ms.
🛡 Collision Force Limiting: Contact torque instantly drops below 5 N within milliseconds upon unexpected touch.
Heavy Vision-Language-Action models struggle with real-time physical obstacles due to inference latency. rMuscle decouples high-level planning from low-level torque reflexes, dropping response latency…
⚙️ Spinal Reflex Decoupling: High-level goals from VLA run at 10 Hz, while local torque reflexes execute at 555 Hz in 1.8 ms.
🛡 Collision Force Limiting: Contact torque instantly drops below 5 N within milliseconds upon unexpected touch.
Reflex Latency: 1.8 ms (555 Hz)
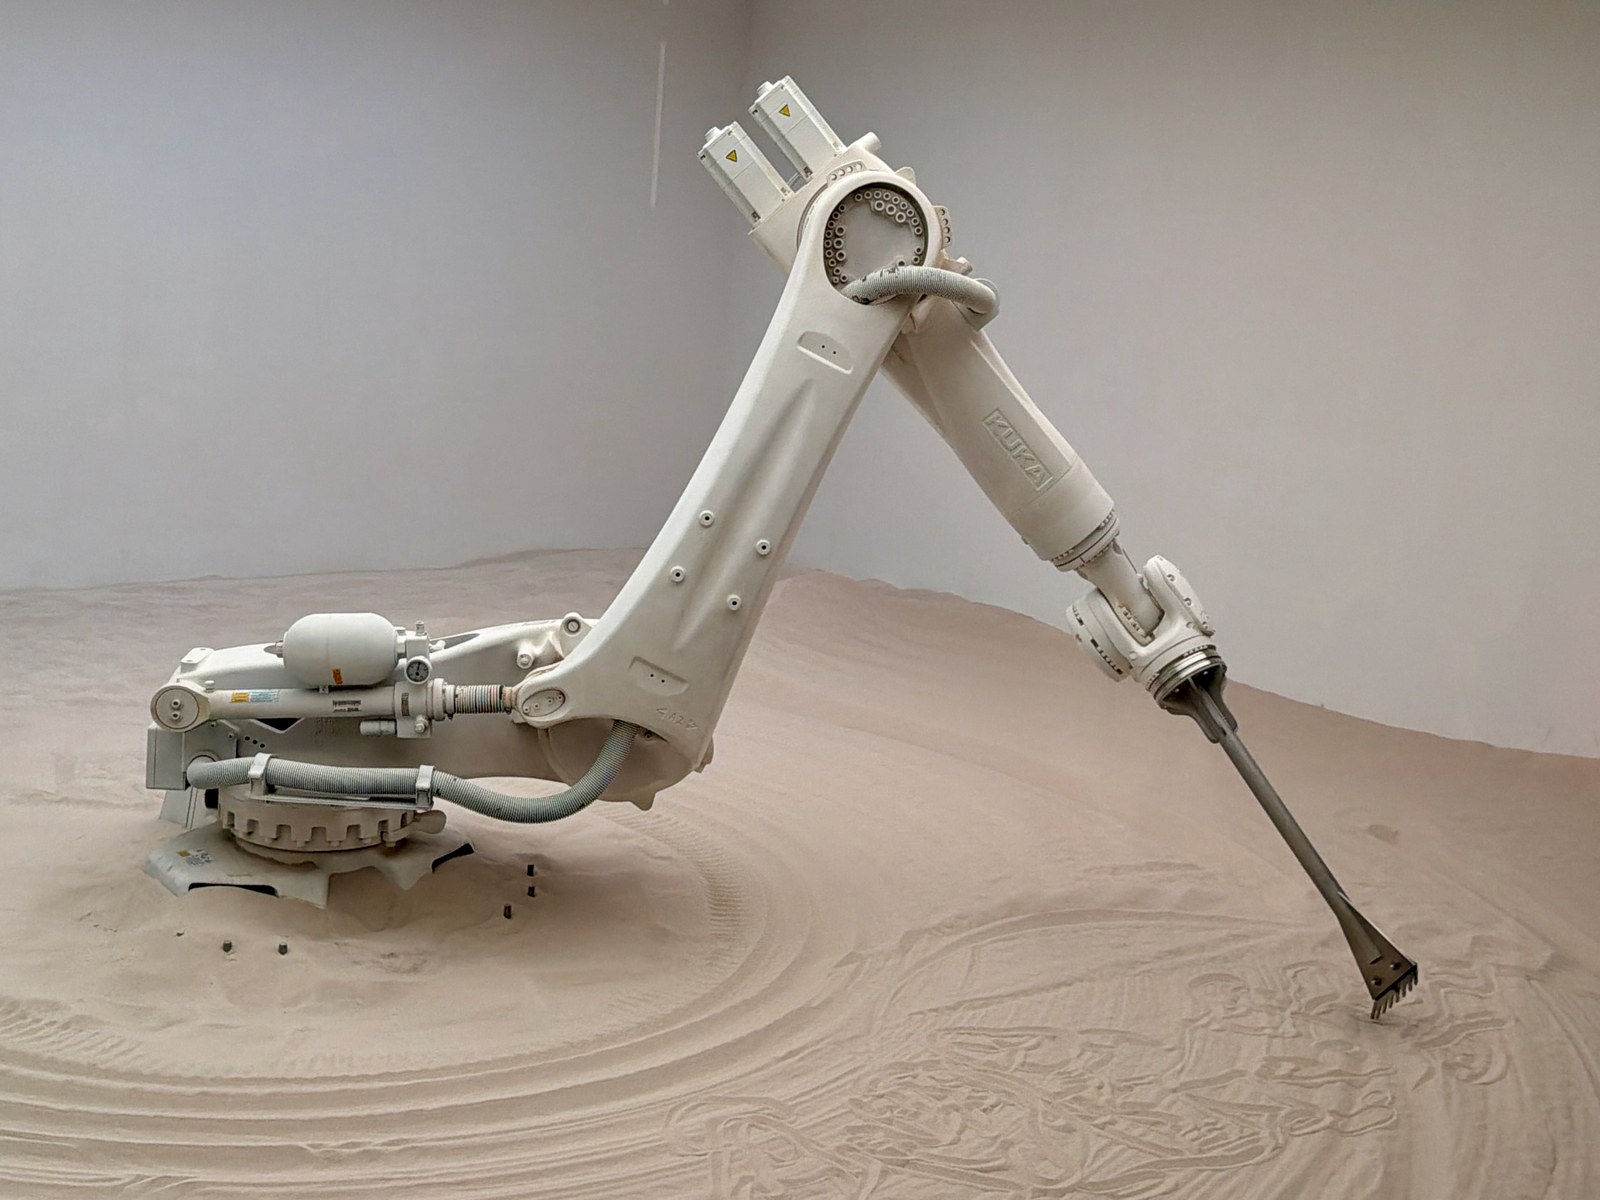
Hardware: KUKA LBR iiwa 7
Repeatability: ±0.05 mm
Heavy Vision-Language-Action models struggle with real-time physical obstacles due to inference latency. rMuscle decouples high-level planning from low-level torque reflexes, dropping response latency to 1.8ms on KUKA iiwa manipulators.
Triples assembly line throughput while eliminating mechanical collision risks.
Regulatory frameworks and infrastructure readiness remain critical.
Collaborative robots will safely operate alongside human technicians at full industrial speed without safety cages.